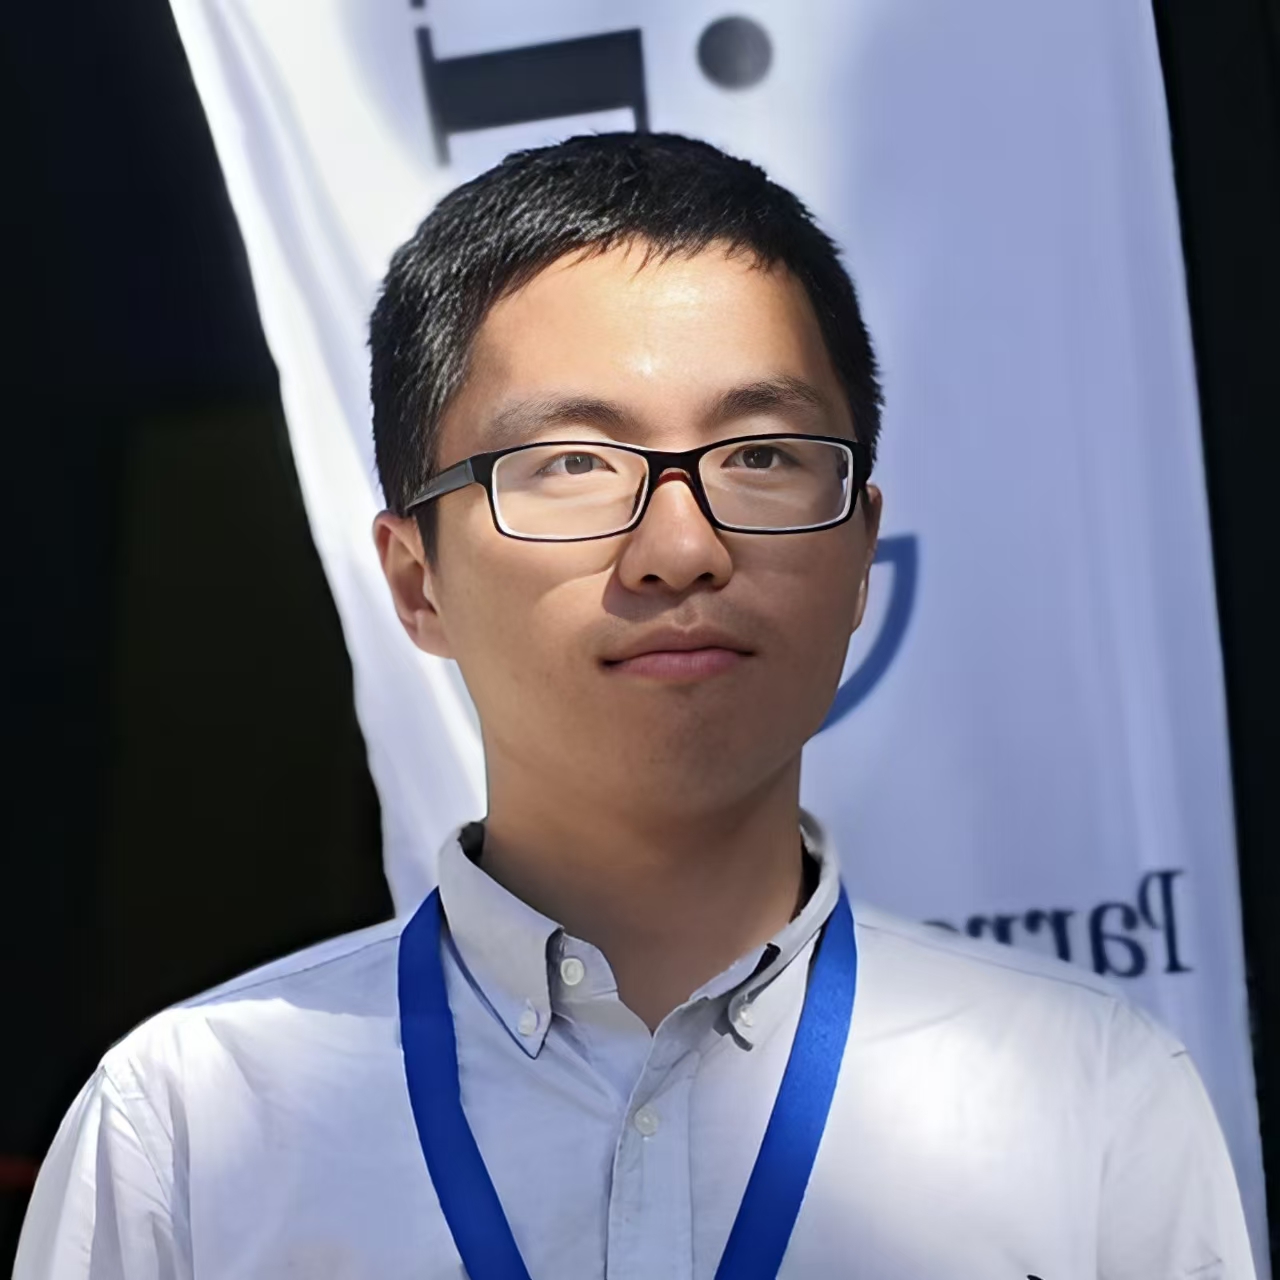
Si Wu
Postdoctoral Researcher, State Key Laboratory of Synthetical Automation for Process Industries, Northeastern University
Nonlinear system stability, safety-critical control, and constraint-satisfaction-based control
About
I am a postdoctoral researcher at the State Key Laboratory of Synthetical Automation for Process Industries, Northeastern University. I received the Ph.D. degree in Control Science and Engineering from Northeastern University in 2025, after earning the M.E. degree in Control Engineering (2020) and the B.E. degree in Automation (2017). My research concerns the feasibility, continuity, and robustness issues in constraint-satisfaction control; I proposed a feasible-set reshaping method and have been working on nonlinear small-gain analysis and constructive safety-critical control. Results have appeared in IEEE Transactions on Automatic Control, Automatica, and IEEE Robotics and Automation Letters, and were presented at IEEE CDC, IROS, and ECC.
News
- 2026Co-authored monograph Robust Safety-Critical Control: Theory, Application and Experiments, to appear with Wiley-IEEE Press.
- 2026Started as PI on an NSFC Young Scientists Fund (Category C) project on robust constraint satisfaction and constructive control for uncertain nonlinear dynamic systems.
- 2026Paper “Constructive safety-critical control of nonlinear cascaded systems with multiple constraints and perturbations” published online in IEEE TAC (full paper).
- 2026Began postdoctoral research at the State Key Laboratory of Synthetical Automation for Process Industries, Northeastern University.
- 2026Paper on set-valued feedback in body-fixed coordinate frame published in IEEE TAC, vol. 71, no. 2.
- 2026Paper “Quadratic-programming-based control of multi-robot systems for cooperative object transport” accepted to the European Control Conference (ECC) 2026.
Publications
Monograph
- T. Liu*, S. Wu, Z. Liu, Z. P. Jiang. Robust Safety-Critical Control: Theory, Application and Experiments. Wiley-IEEE Press, Oct. 2026, 336 pp. (ISBN 978-1-394-40018-8)
Journal Papers
-
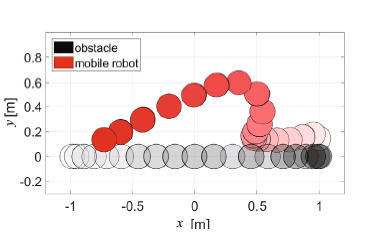
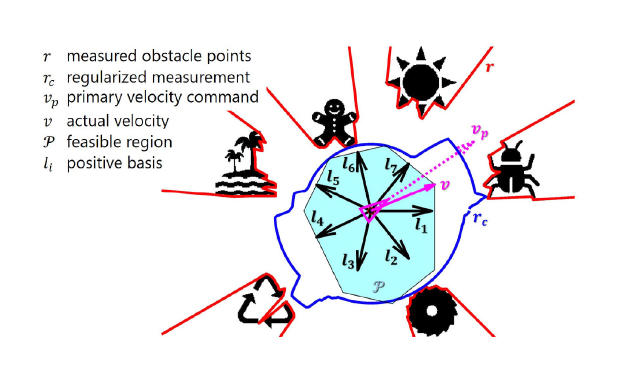
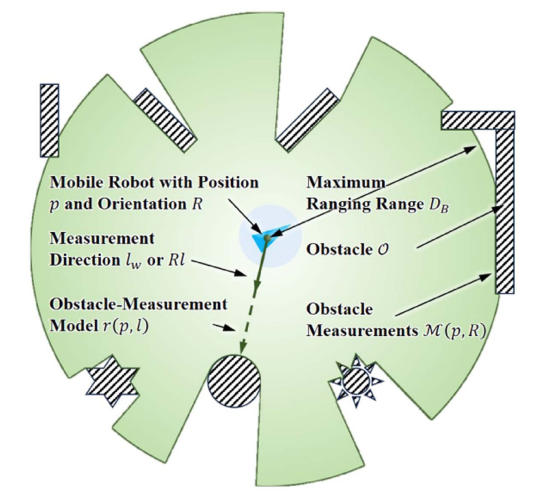 S. Wu, T. Liu*, W. Zhang, J. Ding, Z. P. Jiang, T. Chai. “Continuous safety-critical control of mobile robots with set-valued feedback in body-fixed coordinate frame.” IEEE Trans. Automatic Control, vol. 71, no. 2, pp. 1405–1412, 2026.
-
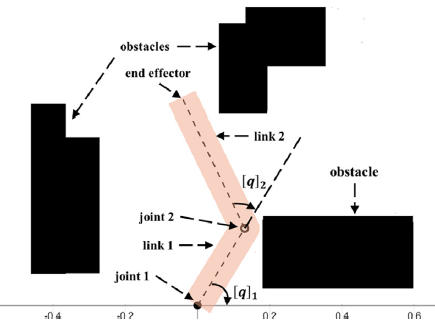 Z. Liu, S. Wu, T. Liu*, Z. P. Jiang. “Continuous safety-critical control of Euler–Lagrange systems subject to multiple obstacles and velocity constraints.” Automatica, vol. 180, Art. 112404, 2025.
-
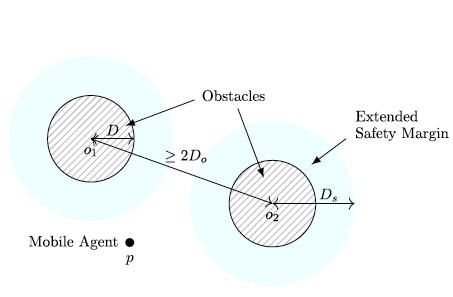 T. Liu*, S. Wu, Z. Liu, Z. P. Jiang. “Safety-critical control under multiple constraints and dynamic uncertainties: A nonlinear small-gain approach.” Unmanned Systems, 2025. (accepted)
-
 S. Wu, T. Liu*. “Safety control of a class of fully actuated systems subject to uncertain actuation dynamics.” Journal of Systems Science & Complexity, vol. 35, no. 2, pp. 543–558, 2022.
-
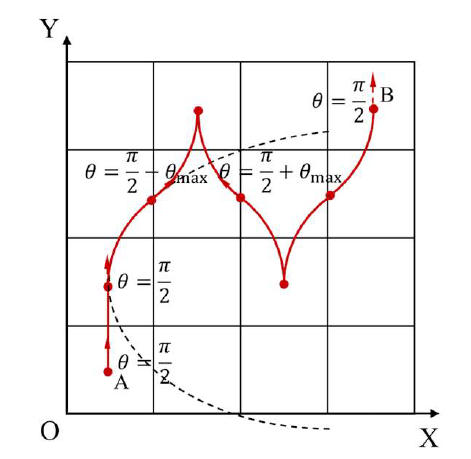 Guo Yating, Wu Si, Xu Qian, Liu Tengfei*, Ding Jinliang. “Path planning for state-constrained nonholonomic mobile robots via improved hybrid A*.” Control Engineering, 2025.
-
Pang Qiang, Wu Si, Niu Bibi, Shi Ruiqi, Li Wenhao, Liu Tengfei*. “IMAV2019 outdoor small UAV control system design and implementation.” Control Engineering, 28(11): 2114–2122, 2021.
-
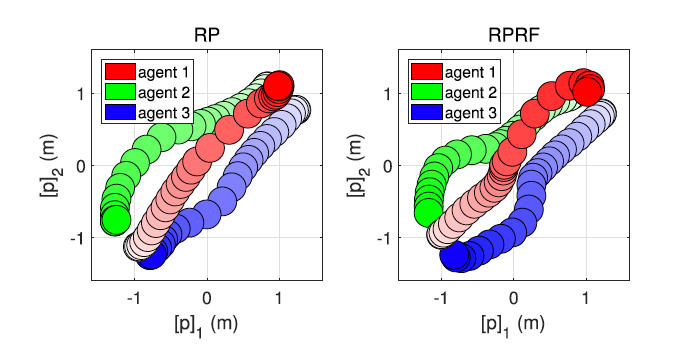
Liu Xiaohui, Wu Si, Liu Tengfei*. “Safety control of multi-agent formation via quadratic programming.” Control Engineering. (accepted).
-
Liu Feiyue, Wu Si, Liu Tengfei*. “Continuous safety control of mobile robots with shape constraints.” Control Engineering. (accepted).
-
Yao Chunpeng, Wu Si, Liu Tengfei*. “Safety control via hierarchical reinforcement learning and control barrier functions.” Control Engineering. (accepted).
Conference Papers
-
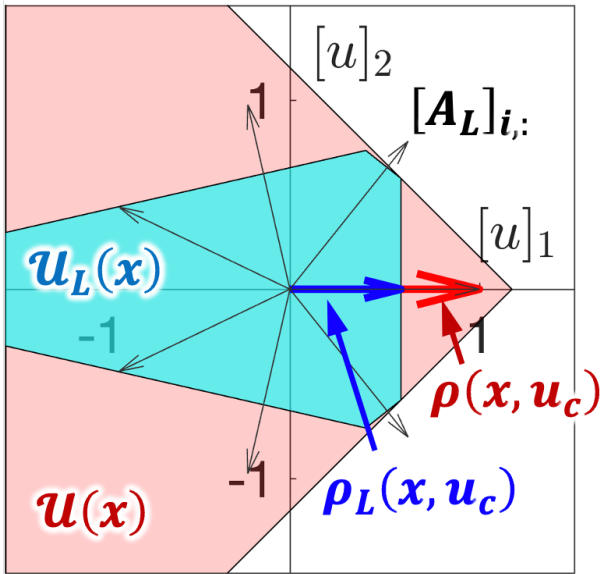 S. Wu, Z. Qin, T. Liu*, Z. P. Jiang. “Quadratic-programming-based control of multi-robot systems for cooperative object transport.” European Control Conference (ECC), 2026. (accepted)
-
S. Wu, T. Liu*, Y. Hong, Z. P. Jiang, T. Chai. “Feasible-set reshaping for constraint qualification in optimization-based control.” IFAC World Congress, 2026. (under review; preprint arXiv:2512.12600)
-
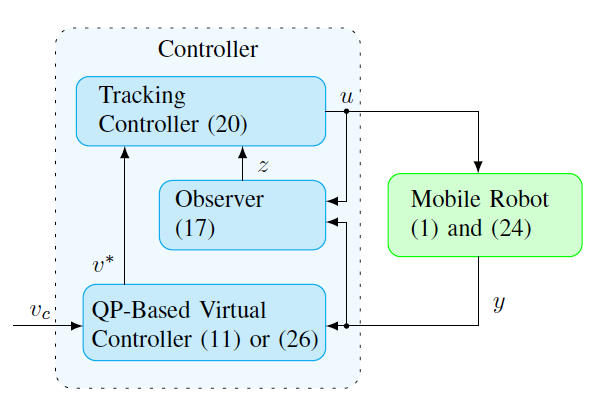 S. Wu, T. Liu*, J. Ding, Y. Li, T. Chai, Z. P. Jiang. “Safe output-feedback control for a class of linear systems with multiple output constraints.” IEEE CDC, pp. 2138–2145, 2025.
-
S. Wu, S. Wang, T. Liu*, Z. P. Jiang. “Safety-critical control of a class of underactuated systems: A case study on wheeled inverted pendulum.” European Control Conference (ECC), 2025.
-
S. Wu, T. Liu*, Z. P. Jiang. “Safety-critical control of a class of underactuated systems: A case study on wheeled inverted pendulum.” Chinese Control Conference (CCC), 2025. (extended abstract).
-
Xu Qian, Wu Si, Liu Tengfei*. “Safety control of nonholonomic mobile robots via switching: case study on unicycle.” CPCC, 2025. (extended abstract).
-
Z. Liu, S. Wu, T. Liu*. “Safety-critical control of Euler–Lagrange systems subject to position and velocity constraints.” CCDC, pp. 1501–1507, 2023.
-
Z. Liu, S. Wu, T. Liu*. “Safety-critical control of Euler–Lagrange systems subject to position constraints.” CCC, pp. 681–686, 2023.
Patents
- 吴思,刘腾飞,丁进良,柴天佑. “Real-time safety control set generation and safety filtering for mobile robots.” CN120848531B. (granted).
- 刘腾飞,潘禹扬,生远修,吴思,丁进良,谢威,张卫东. “Distributed cooperative safety control for multi-agent systems.” CN120044868B. (granted).
- 刘腾飞,刘飞跃,吴思,徐茜. “Robust safety control of mobile systems via LiDAR and barrier functions.” 2024102775094. (pending).
- 刘腾飞,李沅武,温惠钞,吴思,等. “QP-based UAV encirclement control.” 202511142764.9. (filed).
- 刘腾飞,温惠钞,李沅武,吴思,等. “MPC-CBF based UAV formation search and safety control.” 202511114638.2. (filed).
- 刘腾飞,温惠钞,李沅武,吴思,等. “Vision-KF based UAV target localization.” 202511115015.7. (filed).
- 刘腾飞,吴思,李明黎,庞少阳,等. “Communication coordination device and system for motion control experiments.” CN107065684B. (granted).
Projects
As Principal Investigator
- National Natural Science Foundation of China, Young Scientists Fund (Category C), “Robust constraint satisfaction and constructive control for uncertain nonlinear dynamic systems,” PI.
As Participant
- NSFC Key Program, 62333004, “Stability analysis and control of nonlinear systems for integrated multi-level decision and control,” 2024–, participant.
- National Science and Technology Major Project, 2022ZD0119901, “Multi-round cooperative and conflicting game modeling for unmanned system swarms,” 2023–, participant.
Education
- Postdoctoral Researcher, Control Science and Engineering, Northeastern University, State Key Lab of Synthetical Automation, Mar. 2026–present. Advisor: Academician Tianyou Chai.
- Ph.D. Control Science and Engineering, Northeastern University, State Key Lab of Synthetical Automation, 2020–2025. Advisor: Prof. Tengfei Liu.
- M.E. Control Engineering, Northeastern University, 2017–2020. Advisor: Prof. Tengfei Liu.
- B.E. Automation, Henan Polytechnic University, 2013–2017.
Honors
- 2024, CAST Youth Talent Support Program for PhD Students
- 2023, CCDC Zhang Siying Outstanding Youth Paper Award
- 2023, National Scholarship for Ph.D. Students
- 2019, 11th International Micro Air Vehicle Competition (IMAV 2019, Spain) outdoor category, first place
Academic Service
- Reviewer for IEEE Transactions on Automatic Control, Automatica, IEEE Transactions on Industrial Electronics, IEEE/CAA Journal of Automatica Sinica, and Science China Information Sciences.
Contact
Email: wusixstx@163.com
Resume: expsin.github.io/resume
Google Scholar: Si Wu
ORCID: 0000-0003-2339-5511